 ChipApex | Global Electronic Components Supplier
SEARCH
Search Product
Search Post
— IC芯片 | 连接器 | 传感器 | 被动器件 —
Search productSearch post
— IC芯片 | 连接器 | 传感器 | 被动器件 —
Consult the customer manager about the wholesale price.
consultation hotline:86-132-6715-2157
email:[email protected]
Contact the product manager for consultation. One-stop consultation is available.
Do you want a lower wholesale price? Please send us your inquiry and we will reply immediately.
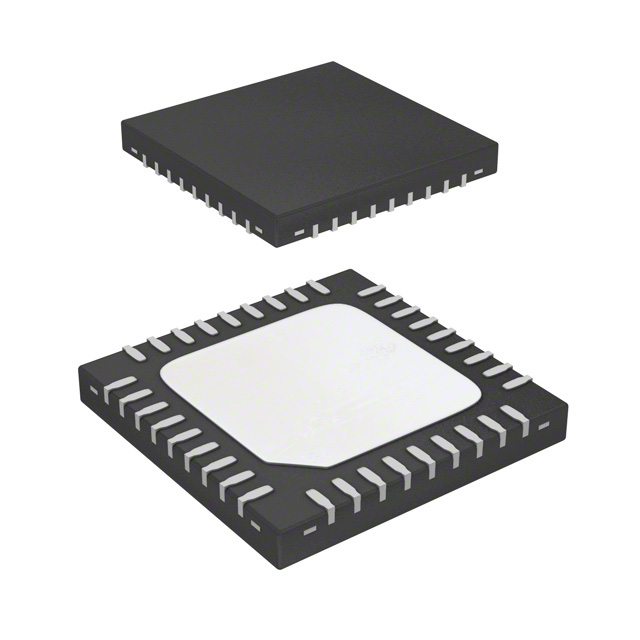
The TC78B011FTG,EL is a three-phase PWM chopper pre-driver IC designed for sensorless brushless DC motors. It operates with an external six-N-channel MOSFET inverter bridge within a supply voltage range of 5.5V to 27V, with absolute maximum ratings up to 30V. The device utilizes a compact P-WQFN36 package featuring 36 pins. It supports sine wave control signals and integrates non-volatile memory (NVM) for parameter storage. Control interfaces include I2C serial communication, analog voltage input, and PWM duty cycle adjustment.
Verify the specific suffix EL against official Toshiba documentation to confirm packaging configuration. Ensure compatibility with the required N-channel MOSFET gate drive specifications. Confirm that the I2C address and register map align with the system design requirements before finalizing procurement.
Select this component when designing sensorless BLDC systems requiring integrated closed-loop control without external processing overhead. The built-in NVM simplifies calibration by storing unique motor characteristics directly on the chip. Consider the P-WQFN36 footprint for space-constrained layouts requiring robust thermal performance.
This part belongs to Toshiba's series of three-phase brushless motor control pre-drivers. It distinguishes itself by combining sine wave commutation logic with digital control interfaces. The integration of advanced protection features and non-volatile memory reduces the bill of materials by eliminating the need for separate EEPROM or complex MCU firmware for basic motor management.
Consult official Toshiba substitution lists for verified equivalents. Generic replacements may lack the specific NVM programming capabilities or sine wave control algorithms inherent to this model.
It detects rotor position by monitoring the back-EMF zero-crossing points of the U-phase during the sine wave commutation process, enabling sensorless operation.
The IC enters an error mode and automatically restarts after a set recovery time. If a stop command is active during the error state, it transitions to idle mode.
 TC78B011FTG,EL
The activity of extra discounts on wholesale prices is in full swing…
Please fill in your contact information and we will send you the latest wholesale price list.