 ChipApex | Global Electronic Components Supplier
SEARCH
Search Product
Search Post
— IC芯片 | 连接器 | 传感器 | 被动器件 —
Search productSearch post
— IC芯片 | 连接器 | 传感器 | 被动器件 —
The trend of science and technology is changing rapidly.
An inertial measurement unit (IMU) measures motion using an accelerometer and a gyroscope in one device or module. The accelerometer senses specific force, including the effect of gravity; the gyroscope senses angular rate. Software can combine their readings to estimate movement and orientation, but the estimate needs calibration and has limits.
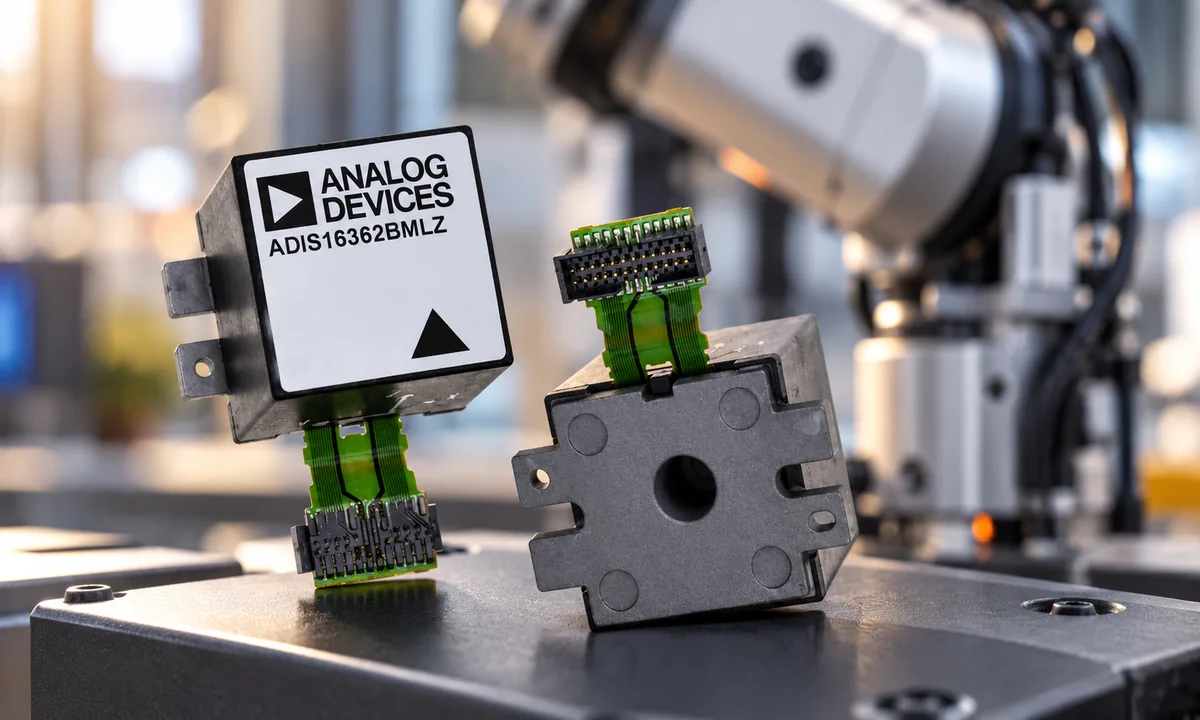
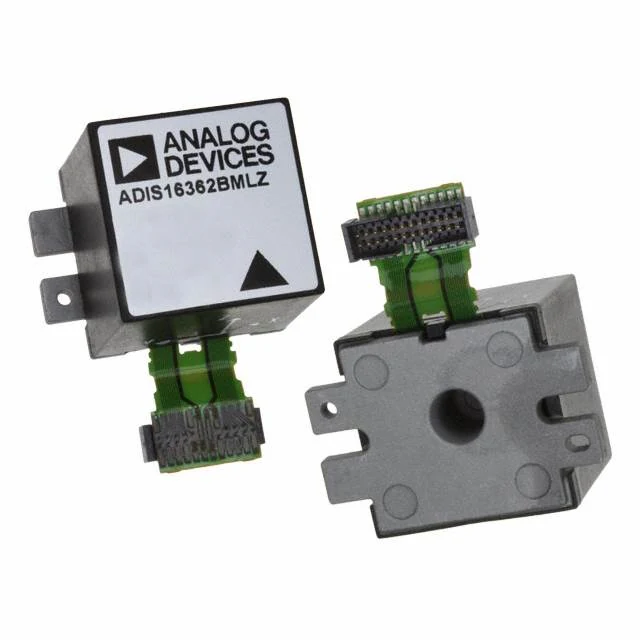
A common six-axis IMU provides acceleration along three axes and rotation rate about three axes. Some products add a magnetometer for a nine-axis system, but the label alone does not tell you what the device actually integrates. Check the block diagram and output registers for the exact part in the ChipApex inertial measurement units category.
An IMU mounted on a robot arm, for example, can report how the assembly accelerates and rotates. Its output is not a direct position measurement. Position estimated by integrating acceleration can drift quickly unless other references correct it.
The gyroscope follows quick rotational changes, but integrating its rate creates angle drift over time. The accelerometers reading can help infer tilt relative to gravity when other acceleration is limited, but it becomes ambiguous during strong motion. Sensor-fusion software weighs those signals according to the application. Even a well-designed six-axis estimate cannot establish true north without another reference.
Six-axis usually refers to three acceleration and three angular-rate channels. Nine-axis generally adds three magnetic-field channels. These are channel counts, not a guarantee of tracking accuracy. Performance depends on sensor noise, bias stability, calibration, sample rate, mounting, magnetic conditions, and the fusion algorithm.
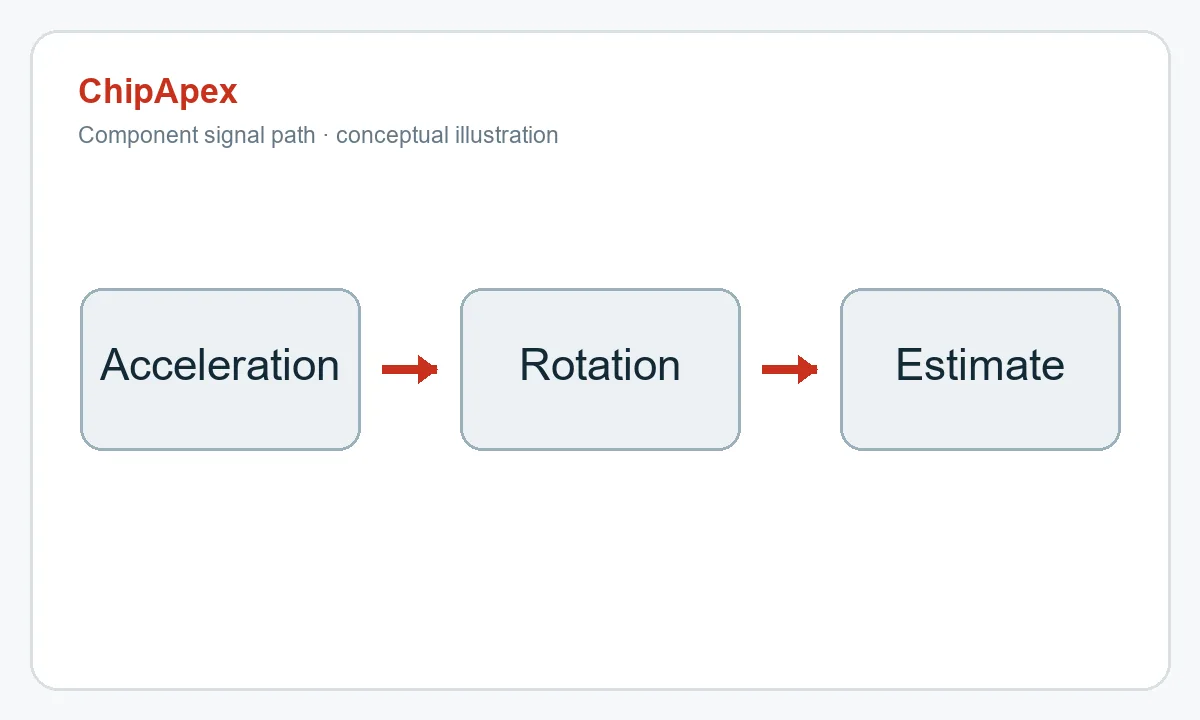
Set the expected acceleration and angular-rate ranges first. Then compare noise, offset or bias, output data rate, power consumption, digital interface, package, temperature limits, and mounting orientation. Verify how firmware handles calibration and timestamps. For sourcing, share the intended motion range, interface, environment, and part number with ChipApex.
No ordinary IMU directly measures absolute position. Integrating motion readings accumulates error, so location estimates need other references.
No. A gyroscope senses angular rate. An IMU usually combines it with an accelerometer and may integrate more sensors.
It can track relative rotation, but yaw drifts without an external heading reference such as a magnetometer or another system cue.
Board mounting and housing stresses can change offsets and alignment. Calibration in the final mechanical assembly can reduce those errors.
Select a bus supported by the host controller and required data rate, then verify voltage levels, interrupt behavior, and driver support in the datasheet.
Discover what DRAM is, how it works, its types, and why choosing authentic, RoHS-compliant DRAM chips matters. Source reliable DRAM from ChipApex—global supplier with full traceability.
View details
Choose a rocker switch by AC/DC ratings, contact arrangement, illumination, panel fit and sealing. Get practical checks for engineering and component sourcing.
View details
Discover why SRAM remains essential in industrial, medical & aerospace systems—thanks to its deterministic performance and long-term reliability. Trusted by engineers worldwide.
View details
A comparator checks which of two input voltages is higher and changes its output state accordingly. It is useful when an analog signal must trigger a clear decision, such as an overvoltage warning or sensor threshold. Its input range, output type,...
View details
The activity of extra discounts on wholesale prices is in full swing…
Please fill in your contact information and we will send you the latest wholesale price list.